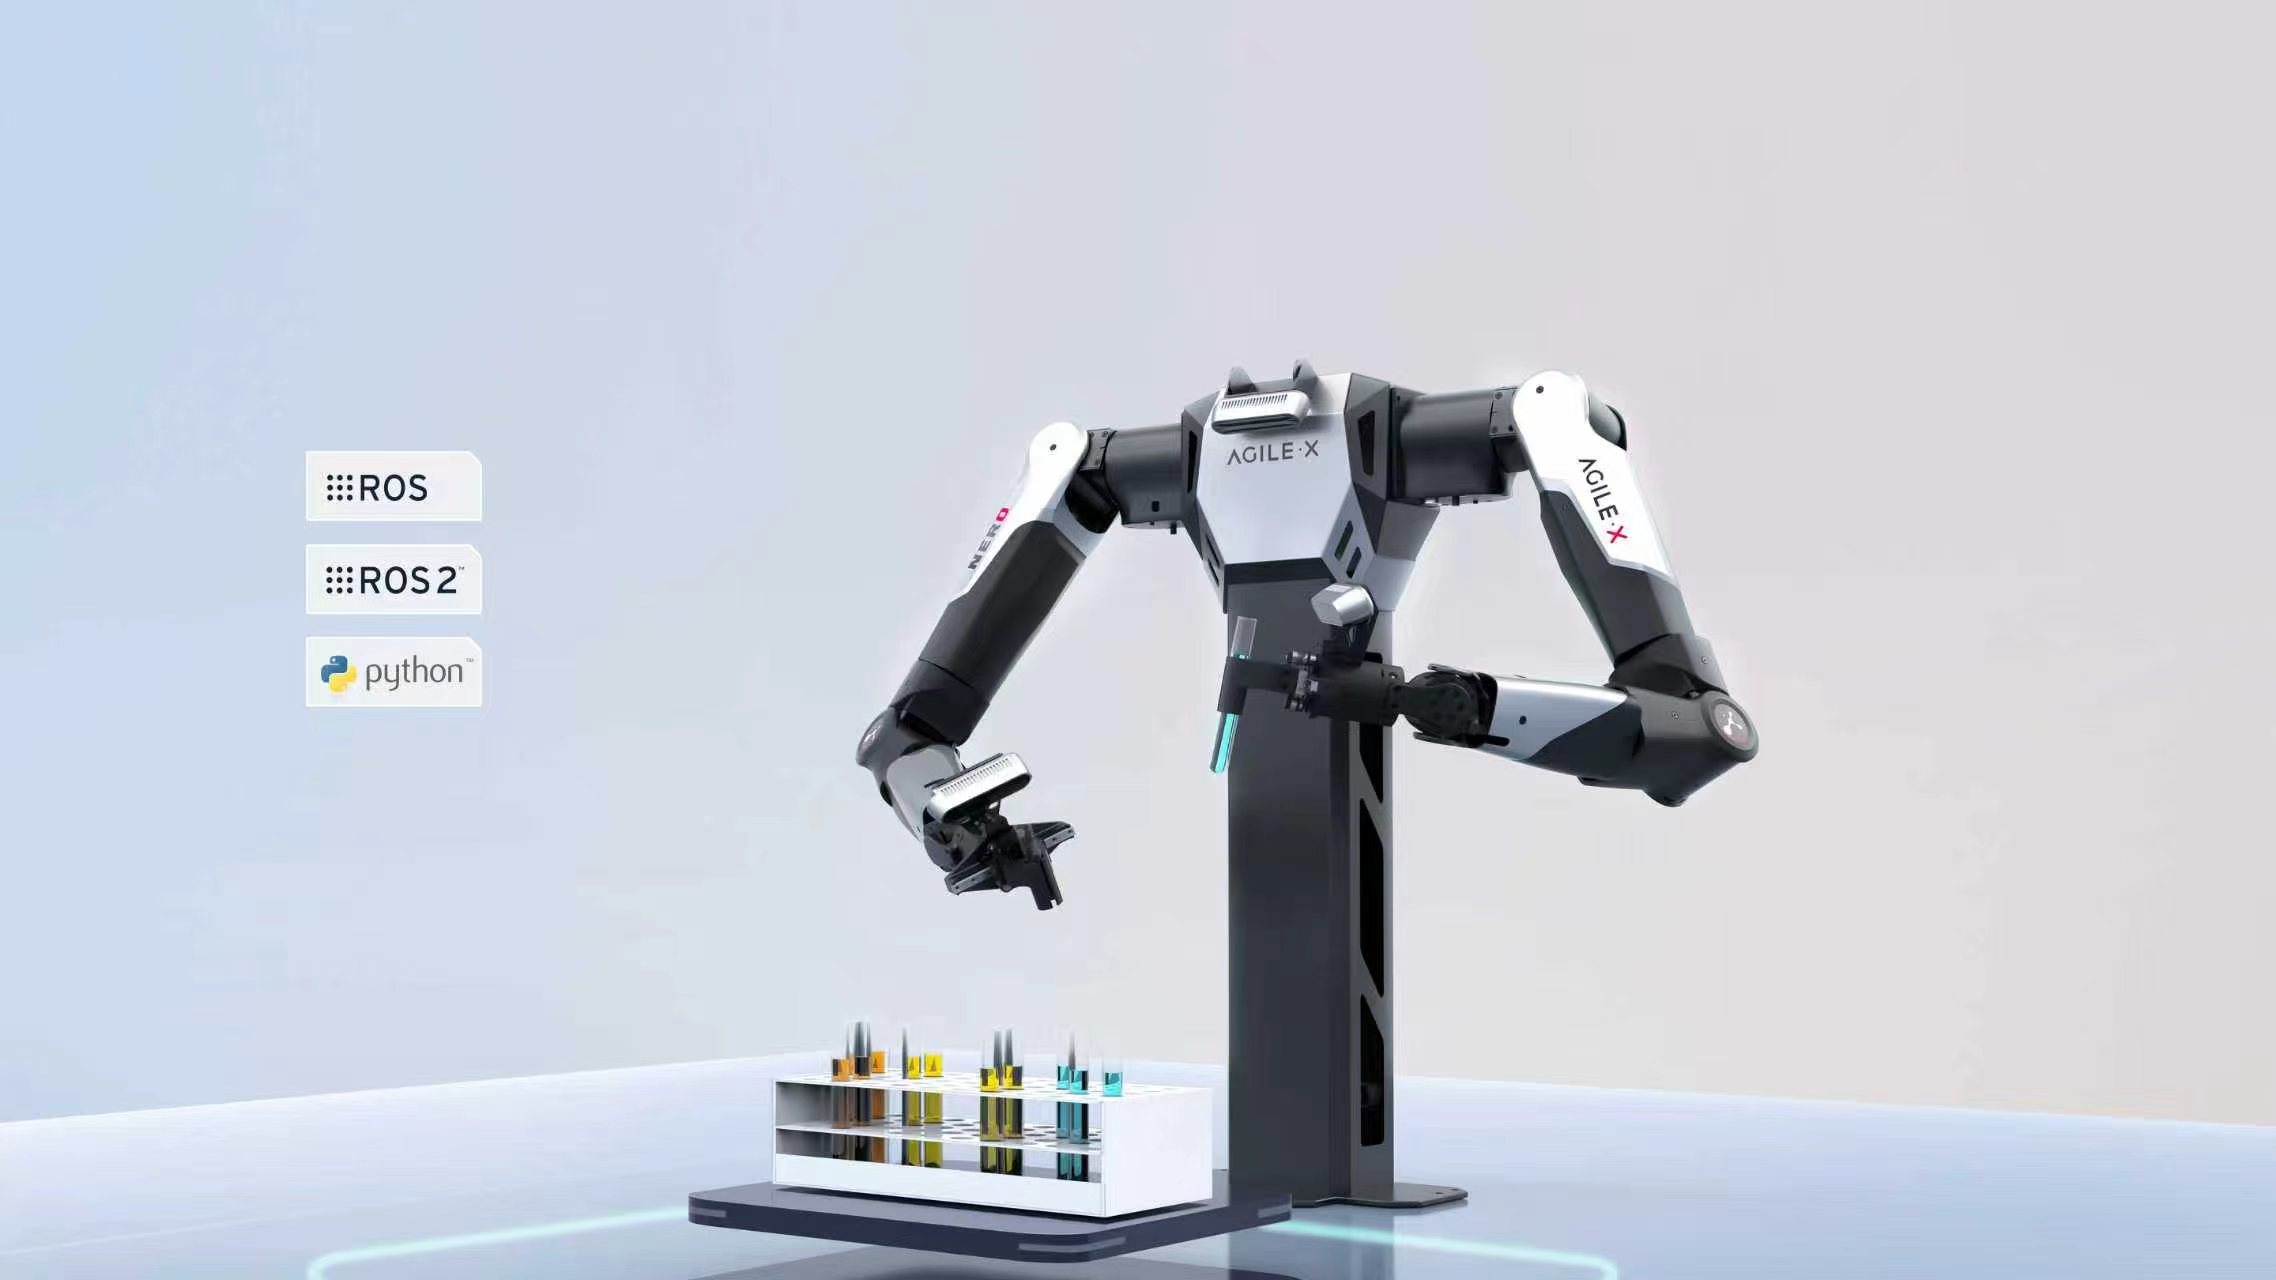
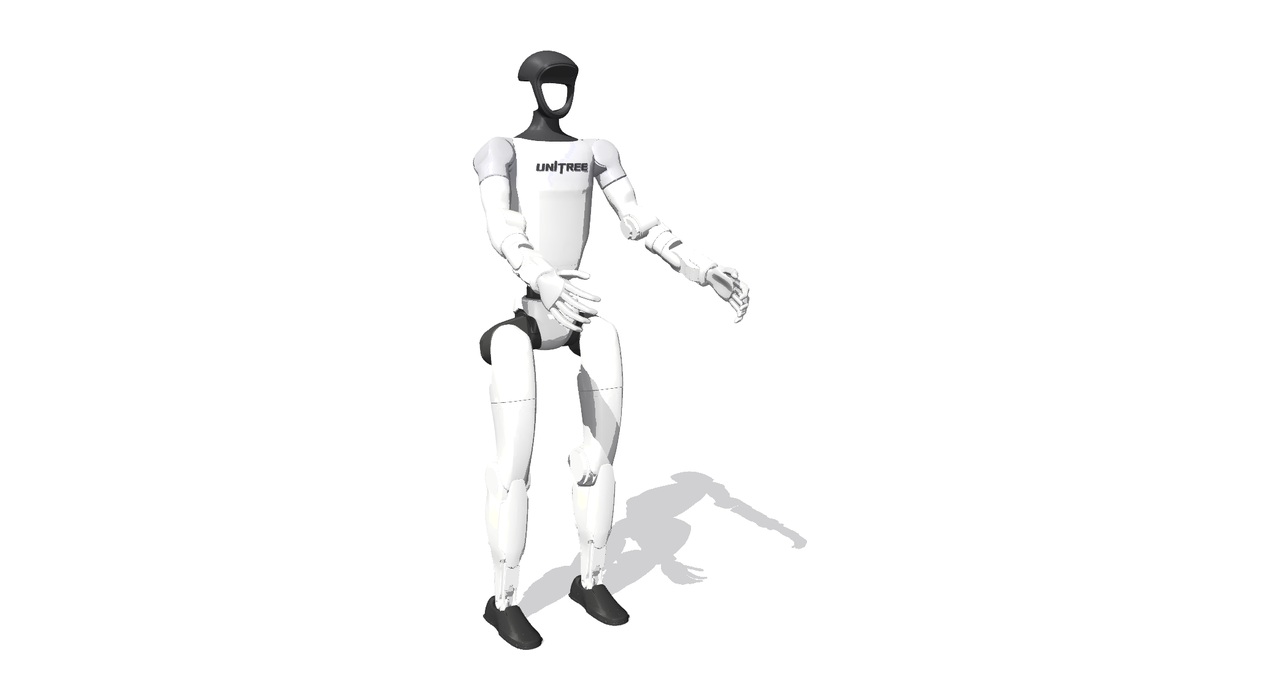
- Which platforms, and which tasks?
- The two platforms above, plus bring-your-own. There is no fixed task list — demos live within tabletop manipulation, mobile manipulation and navigation, and within that scope you propose the task and bring the props it needs. Tell us early if it needs anything from the venue.
- Do we get raw camera data?
- Yes — raw images from the robot’s onboard camera, with calibration. We recommend bringing your own camera and mount if your method depends on a specific sensor or viewpoint.
- What does the API expose?
- Robot control and raw sensor streams, nothing above them. There are no object IDs, no pixel-to-grasp service and no manipulation primitives — perception, grounding and skill construction are the demo, not the scaffolding.
- Is there a simulator before the workshop?
- The SDKs and reference simulations above are public today. A workshop scene matching the station is coming soon and will be linked here.
- What compute should we plan for?
- Bring your own laptop or workstation and run whatever you like on it — your models, your stack, your environment. The station provides power and a wired drop.
- Can the submission video be simulation-only?
- Yes, with physical integration after acceptance — except for the provided Unitree G1, where physical-robot video is the eligibility bar.
- Can the same project go to both the Poster and Demo tracks?
- Yes.
- Are the tracks archival?
- No. Contributing here does not preclude submitting the full manuscript to a journal or another archival venue later.
- What is the deadline?
- September 27, 2026, 11:59 PM Anywhere on Earth, via OpenReview.