Platform A / AgileX Robotics
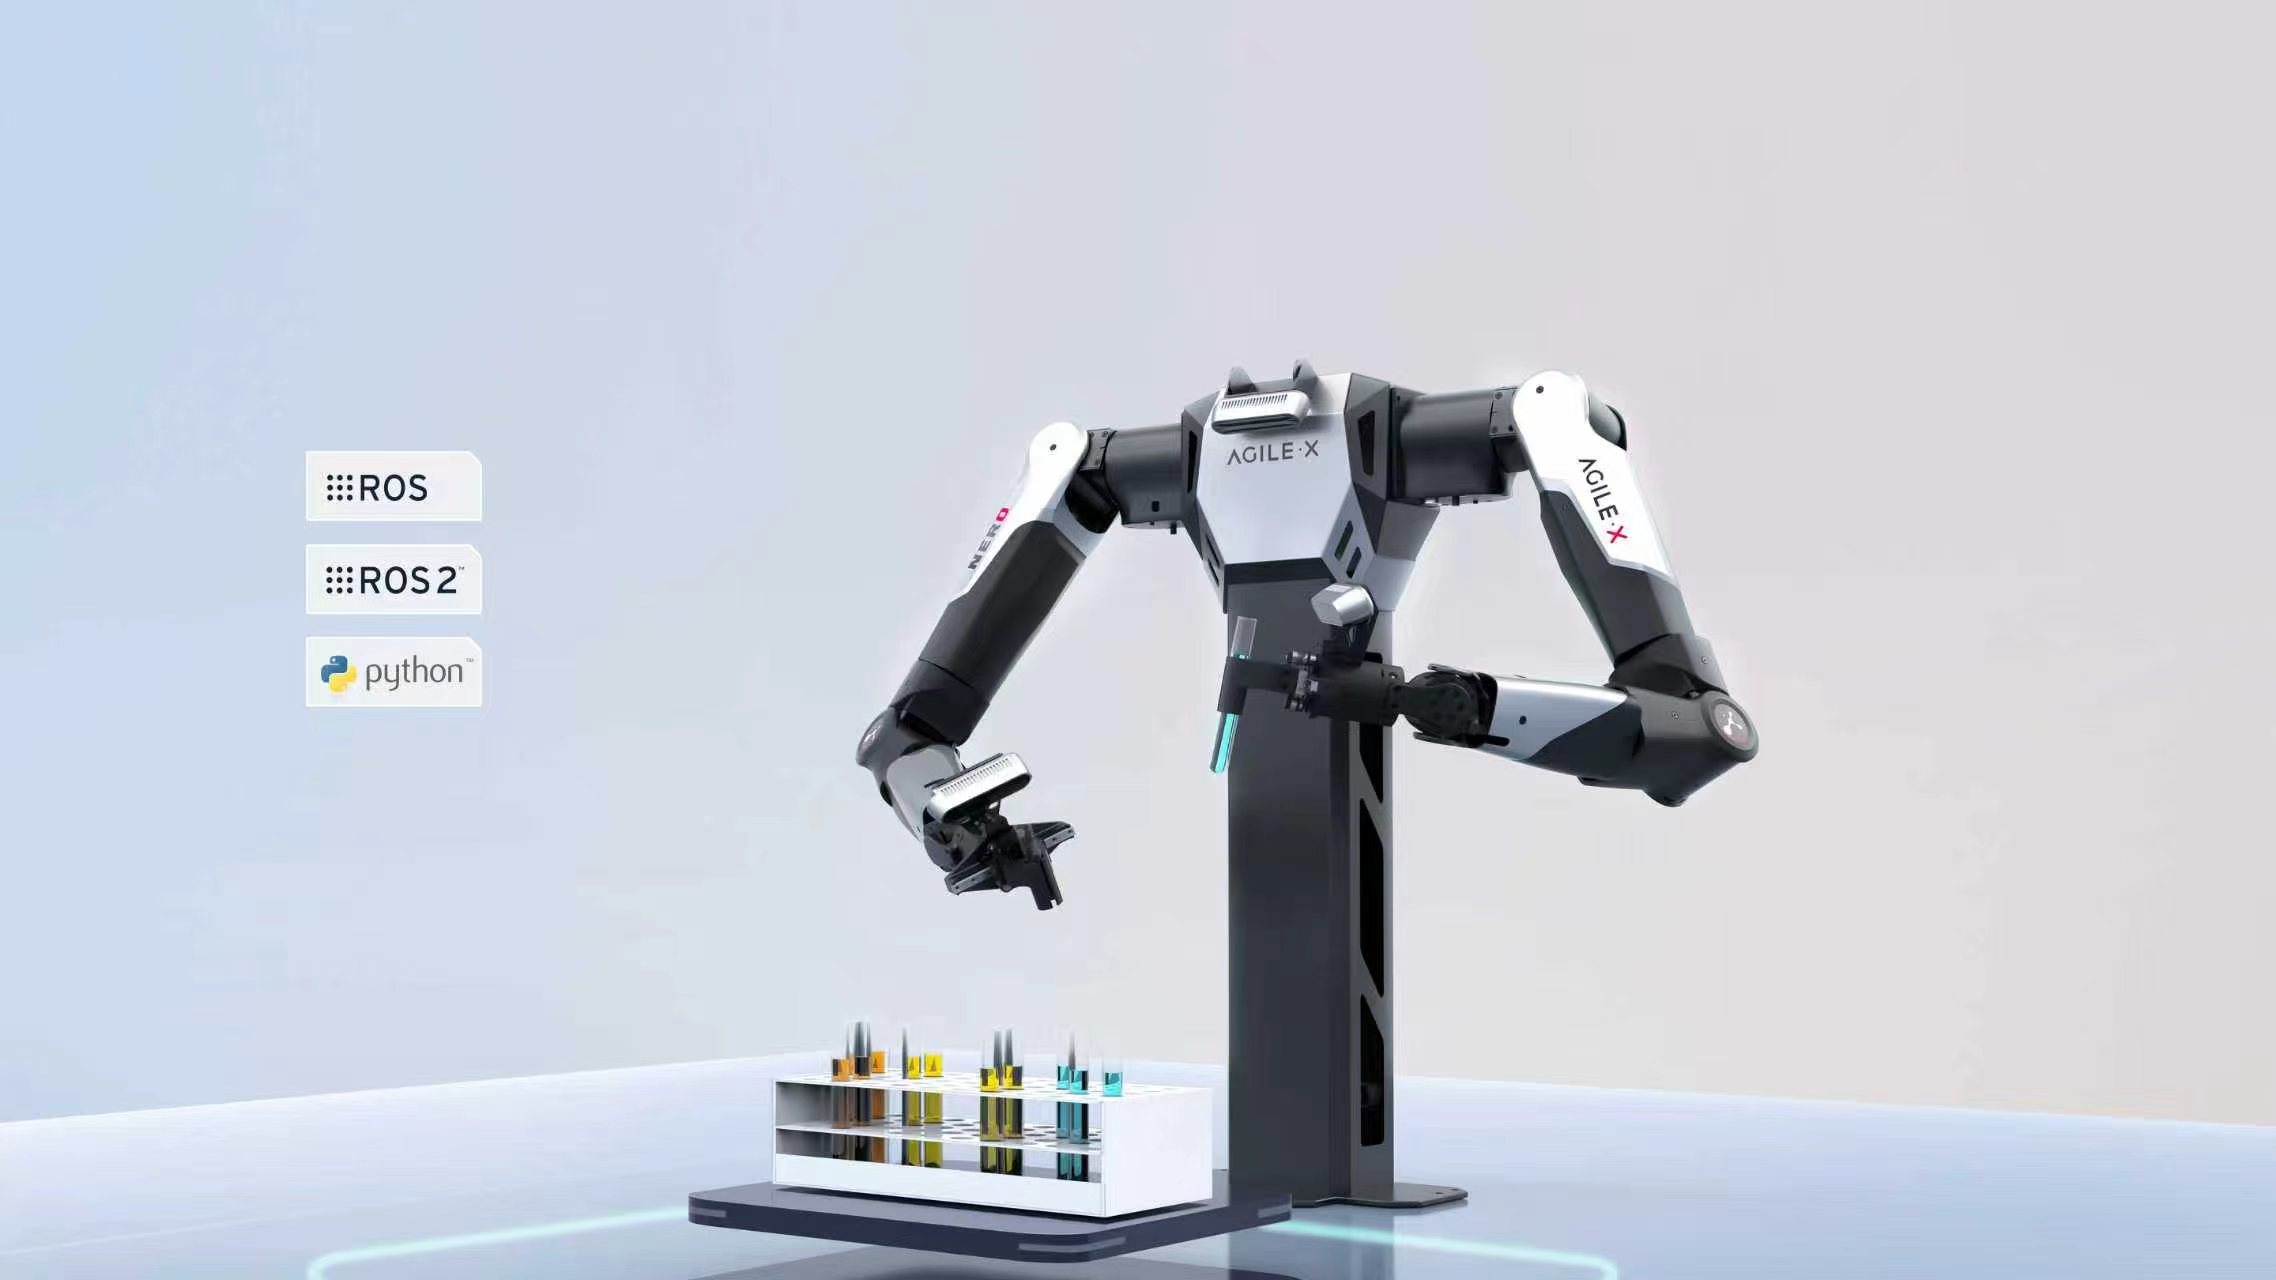
Dual-arm AgileX NERO
Two 7-DoF NERO arms on a shared column — the default tabletop and bimanual station, with a parallel-jaw gripper or a Revo2 dexterous hand per arm. Open to every accepted demo; no prior experience required.
Start developing in simulation
Participant preview: build your code-as-policy or agent-as-policy demo with the shared NERO Python and MCP interfaces. Follow the Linux x86_64 quick start, then test against the simulator before coordinating hardware integration with the organizers.
- Arms
- 2 × NERO, 7 DoF, 3 kg / 580 mm each
- End-effector
- AgxGripper or Revo2 hand
- Bus
- CAN
- Teleoperation
- Optional leader–follower lead arm
- Workshop Python API and MCP tools support code-as-policy and agent-as-policy through the same interfaces in simulation and on hardware: RGB-D capture, pixel deprojection, official AgileX IK/FK, joint/TCP motion, independent gripper control, and measured operation feedback.
- MuJoCo participant simulator includes place, select, and sort tasks, a live dashboard, and example Python and MCP policies. The reference setup uses two NERO arms with parallel-jaw grippers and one stand-mounted ZED 2i RGB-D camera; there are no wrist cameras. These examples do not establish Revo2 hand support.
- Start on Linux x86_64. Generated Python execution also requires Landlock ABI ≥3 and libseccomp. Use the simulator first and coordinate physical integration with the organizers. The shared controller does not provide obstacle-avoidance planning.